CHAPTER
11
More on Numerical Methods for
Unconstrained Optimum Design
Section 11.1 More on Step Size Determination
11.2 ______________________________________________________________________________
11.3 _______________________________________________________________________________
discontinuous, non-smooth, and non-unimodal functions
11.4 ______________________________________________________________________________
c =
f()
xÑ
= (−1 + x2, x1+ 2x2) = (3, 10) c•d = −13 < 0; d is a direction of descent.
2 − 13
Section 11.4 Search Direction Determination: Newton’s Method
11.10_____________________________________________________________________________
2. c(0) = (2x1− 4 − 2x2, 4x2− 2x1) = (− 4, 2), ||c(0)|| = 20 > ε
3. H(0) =
22
24
−
−
, H(0) is positive definite.
4. d(0) = − H(0)-1c(0) = (3, 1), (c(0)•d(0)) = − 10 < 0. The descent condition is satisfied.
2 − 10
11.11______________________________________________________________________________
2. c(0) = (24.192x1 − 1.7321, 43.008x2 − 1) = (22.4599, 42.008), ||c(0)|| = 47.6 > ε
3. H(0) =
24.192 0
0 43.008
, H(0) is positive definite.
4. d(0) = − H(0)-1c(0) = (− 0.928402, − 0.976749), d(0) is a descent direction.
5. x(1) = x(0) +
α
d(0) = (1 − 0.928402
α
, 1 − 0.976749
α
) ;
11.12______________________________________________________________________________
2. c(0) = (13.966x1− 1, 24.83x2) = (26.932, 24.83), ||c(0)|| = 36.63 > ε
3. H(0) =
13.966 0
0 24.83
, H(0) is positive definite.
4. d(0) = − H(0)-1c(0) = (− 1.928396, −1), d(0) is a descent direction.
5. x(1) = x(0) +
α
d(0) = (2 − 1.928396
α
, 1−
α
); f (
α
) = f (x(0) +
α
d(0)) = 6.983(2 − 1.928396
α
)2 +
x(1) = (0.071604, 0)
6. k = k + 1, go to step 2.
11.13______________________________________________________________________________
2. c(0) = (24.192x1, 43.008x2− 1) = (24.192, 85.016) , ||c(0)|| = 88.391 > ε
3. H(0) =
24.192 0
0 43.008
, H(0) is positive definite.
4. d(0) = − H(0)-1c(0) = (− 1, − 1.9767485), d(0) is a descent direction.
5. x(1) = x(0) +
α
d(0) = (1−
α
, 2 − 1.9767485
α
); f (
α
) = f (x(0) +
α
d(0)) = 12.096(1−
α
)2 +
x(1) = (0, 0.0232515)
11.14______________________________________________________________________________
2. c(0) = (50x1− 2, 40x2 − 1) = (148, 39), ||c(0)|| = 153.05 > ε
3. H(0) =
50 0
0 40
, H(0) is positive definite.
4. d(0) = − H(0)-1c(0) = (− 2.96, − 0.975), d(0) is a descent direction.
x(1) = (0.04, 0.025)
11.15______________________________________________________________________________
1. x(0) = (1, 1, 1), k = 0, ε = 0.001
2. c(0) = (2x1 + 2x2, 4x2 + 2x1 + 2x3, 4x3 + 2x2) = (4, 8, 6), ||c(0)|| = 10.77 > ε
3. H(0) =
220
242
024
, H(0) is positive definite.
4. d(0) = − H(0)-1c(0) = (−1, −1, −1), d(0) is a descent direction.
5. x(1) = x(0) +
α
d(0) = (1−
α
, 1−
α
, 1−
α
); f (
α
) = f (x(0) +
α
d(0)) = 9(1−
α
)2;
f ‘(
α
) = − 18(1−
α
) = 0,
α
11.16______________________________________________________________________________
1. x(0) = (4, 6), k = 0, ε = 0.001
5.929724 8.643596
−
4. d(0) = − H(0)-1c(0) = (− 104.936473, − 80.082574), d(0) is a descent direction.
5. x(1) = x(0) +
α
d(0) = (4 − 104.936473
α
, 6 − 80.082574
α
); f (
α
) = f (x(0) +
α
d(0))
= 8(4 − 104.936473
α
)2 + 8(6 − 80.082574
α
)2 − 5(10 − 185.019047
α
)
22
11.17______________________________________________________________________________
1. x(0) = (5, 2), k = 0, ε = 0.001
2.474302 13.877611
−
4. d(0) = − H(0)-1c(0) = (− 1.381415, − 1.871686), d(0) is a descent direction.
5. x(1) = x(0) +
α
d(0) = (5 − 1.381415
α
, 2 − 1.871686
α
); f (
α
) = f (x(0) + αd(0))
= 9(5 − 1.381415
α
)2 + 9(2 − 1.871686
α
)2 − 5(5 − 1.381415
α
) − 41(2 − 1.871686
α
)
22
− 64
22
(5 1.381415 ) (2 1.871686 ) 16(2 1.871686 ) 64
αα α
− +− + − +
;
Equal Interval Search gives
α
0 = 0.889257; x(1) = (3.771567, 0.335589)
6. k = k + 1, go to step 2.
11.18______________________________________________________________________________
1. x(0) = (5, 2), k = 0, ε = 0.001
2. c(0) = {− 400x1(x2 − x
2
1
) − 2(1 − x1), 200(x2 − x
2
1
)} = (46008, − 4600); ||c(0)|| = 46237 > ε
3. H(0) =
29202 2000
2000 200
−
−
, H(0) is positive definite.
4. d(0) = − H(0)-1c(0) = (− 0.00086938, 22.991306); d(0) is a descent direction.
5. x(1) = x(0) +
α
d(0) = (5 − 0.00086938
α
, 2 + 22.991306
α
); f (
α
) = f (x(0) +
α
d(0))
11.19______________________________________________________________________________
1. x(0) = (1, 2, 3, 4), k = 0, ε = 0.001
2. c(0) = {2(x1− 10x2) + 40(x1 − x4)3, − 20(x1− 10x2) + 4(x2 − 2x3)3, 10(x3 − x4) − 8(x2 − 2x3)3,
Chapter 11 More on Numerical Methods for Unconstrained Optimum Design
Section 11.5 Search Direction Determination: Quasi – Newton Methods
11.22______________________________________________________________________________
DFP Iteration 2: x(1) = (2, 0.5)
2. c(1) = (− 1, − 2), ||c(1)|| = 5 > ε, so continue
3. A(1) =
0.84 0.38
0.38 0.41
; d(1) = − A(1)c(1) = (1.6, 1.2)
6. c(2) = (0, 0), ||c(2)|| = 0, x(2) is the optimum point.
11.23______________________________________________________________________________
DFP iteration 2: x(1) = (0.42151, − 0.08198)
2. c(1) = (8.4651, − 4.5259), ||c(1)|| = 9.6 > ε, so continue
3. A(1) =
0.9228 0.2651
0.2651 0.1030
−
−
; d(1) = − A(1)c(1) = (− 9.0111, 2.710)
6. c(2)
(0, 0), ||c(2)|| = 0
11.24______________________________________________________________________________
2. c(1) = (7.0912, − 7.6915), ||c(1)|| = 10.5 > ε
3. A(1) =
0.7573 0.4183
0.4183 0.2955
−
−
; d(1) = − A(1)c(1) = (− 8.5875, 5.239)
6. c(2) = (0, 0), ||c(2)|| = 0
11.25______________________________________________________________________________
DFP iteration 2: x(1) = (0.41844, − 0.04373)
5. x(2) = (0, 0.02325)
11.26______________________________________________________________________________
DFP iteration 2: x(1) = (0.0010536, 0.20974)
5. x(2) = (0.04, 0.025)
11.27______________________________________________________________________________
DFP iteration 2: x(1) = (0.38298, − 0.23404, 0.074468)
3. A(1) =
0.9032 0.2132 0.1648
0.2132 0.5310 0.3624
0.1648 0.3624 0.7200
−−
−−
−−
; d(1) = − A(1)c(1) = (− 0.302, 0.0131, 0.164)
5. x(2) = (0.2571, − 0.2286, 0.1428)
y(1) = c(2) − c(1) = (− 0.2409, − 0.09332, 0.2842)
11.28______________________________________________________________________________
DFP iteration 2: x(1) = (5.338509, 0.482583)
0.27162 0.16695
4. x(2) = x(1) +
α
d(1) = (5.338509 − 4.86364
α
, 0.482583 − 1.55249
α
); f (
α
) = f (x(1) +
α
d(1));
Golden section search gives α1 = 0.19904
5. x(2) = (4.37045, 0.173575)
11.29______________________________________________________________________________
DFP iteration 2: x(1) = (4.751894, 0.343496)
5. x(2) = (3.73707, 0.28550)
11.30______________________________________________________________________________
DFP iteration 2: x(1) = (−1.4411, 2.644)
0.102 0.99
4. x(2) = x(1) +
α
d(1) = (− 1.4411 − 13.604242
α
, 2.644 − 130.6464
α
); f (
α
) = f (x(1) +
α
d(1));
Golden section search gives α1 = 0.0346748.
5. x(2) = (− 1.912824, − 1.886134)
11.31______________________________________________________________________________
DFP iteration 2: x(1) = (3.07233, 1.77015, 2.06949, 1.97957)
2. c(1) = (22.93732, 239.414, 107.238, − 53.095), ||c(1)|| = 269 > ε
0.53219 0.047504 0.16177 0.46871
0.047504 0.99522 0.016446 0.047591
−
−
11.34______________________________________________________________________________
BFGS iteration 2: x(1) = (0.42151, − 0.08198)
5. x(2) = (0.07160, 0.02325)
11.35______________________________________________________________________________
BFGS iteration 2: x(1) = (0.57939, − 0.30973)
5. x(2) = (0.0716, 0.0)
11.36______________________________________________________________________________
BFGS iteration 2: x(1) = (0.41844, − 0.04373)
5. x(2) = (0, 0.02325)
11.37______________________________________________________________________________
BFGS iteration 2: x(1) = (0.0010536, 0.20974)
5. x(2) = (0.04, 0.025)
6. c(2) = (0, 0), ||c(2)|| = 0
11.38______________________________________________________________________________
BFGS iteration 2: x(1) = (0.38298, − 0.23404, 0.074468)
2. c(1) = (0.2979, − 0.02128, − 0.1702), ||c(1)|| = 0.344 > ε, so continue.
3. H(1) =
1.6280 1.3837 1.0697
1.3837 4.0440 2.3522
1.0697 2.3522 2.8173
; H(1)d(1) = − c(1), d(1) = (− 0.3020, 0.01313, 0.1641)
4. Step size
α
11.39______________________________________________________________________________
BFGS iteration 2: x(1) = (5.338509, 0.482583)
3. H(1) = ; H(1)d(1) = − c(1), d(1) = (− 4.8882, − 1.56033)
4. Step size
α
11.40______________________________________________________________________________
BFGS iteration 2: x(1) = (4.751894, 0.343496)
0.956 14.186
−
4. Step size
α
11.41______________________________________________________________________________
BFGS iteration 2: x(1) = (− 1.4411, 2.644)
6. c(2) = (− 3.908053, − 0.5005836), ||c(2)|| = 3.94
11.42______________________________________________________________________________
BFGS iteration 2: x(1) = (3.07233, 1.77015, 2.06949, 1.97957)
3. H(1) =
260.120 26.310 89.6075 259.6225
26.31 3.6506 9.1085 26.3584
89.6075 9.1085 31.9827 89.7825
259.6225 26.3584 89.7825 261.1256
−−
−−
−−
−−
;
4. Step size
α
1 = 0.0059653
6. c(2) = (38.656, − 51.580, 99.792, − 31.144), ||c(2)|| = 123
11.43______________________________________________________________________________
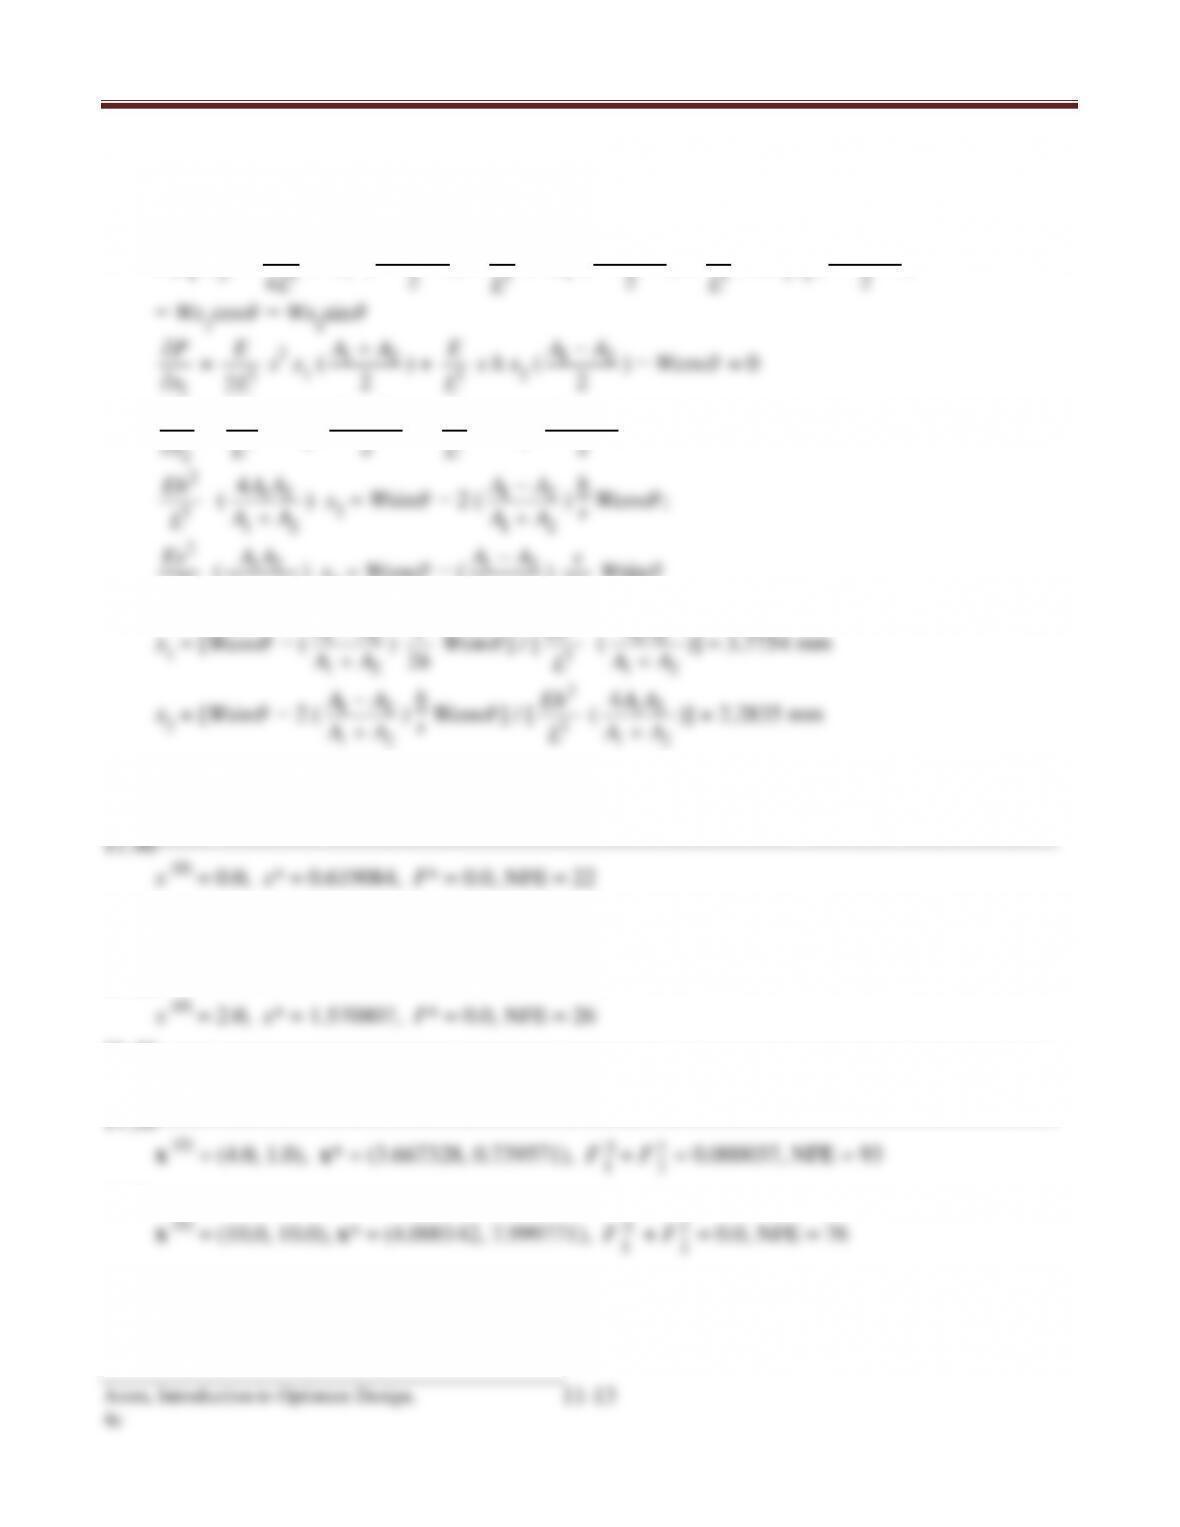
(10.53) x* = (0.071596, 0.023251), f * = − 0.073633;
(10.55) x* = (0.0, 0.023251), f * = − 0.011626;
(10.57) x* = (0, 0, 0), f * = 0;
(10.59) x* = (3.732882, 0.34114), f * = − 1526.55649;
Chapter 11 More on Numerical Methods for Unconstrained Optimum Design
Section 11.6 Engineering Applications of Unconstrained Methods
11.44______________________________________________________________________________
P(x1, x2) =
3
4
E
L
s2 x
2
1
(
12
2
+AA
) +
3
E
L
h2 x
2
2
(
12
2
+AA
) +
3
E
L
s h x1x2 (
12
2
−
AA
)
1
x
∂
3
2
L
2
3
L
2
2
P
x
∂
∂
=
3
2E
L
h2 x2 (
12
2
+AA
) +
3
E
L
s h x1 (
12
2
−AA
) − Wsin
θ
= 0
2
3
Eh
L
12
12
4
+
AA
AA
12
12
−
+
AA
AA
s Wcos
2
3
Es
L
(
12
12
+
AA
AA
) x1 = Wcos
θ
− (
12
12
−
+
AA
AA
)
2
s
h
Wsin
θ
+
AA
12
−
AA
2
Eh
12
−
AA
s
2
Es
12
AA