Chapter 8 – Nonlinear Optimization Models
True / False
1. A nonlinear optimization problem is any optimization problem in which at least one term in the objective function or a
constraint is nonlinear.
a.
True
b.
False
True
1
Introduction
2. A function is quadratic if its nonlinear terms have a power of 4.
a.
True
b.
False
False
1
3. Nonlinear programming algorithms are more complex than linear programming algorithms.
a.
True
b.
False
True
1
A constrained problem
4. Many linear programming algorithms such as the simplex method optimize by examining only the extreme points of the
feasible region.
a.
True
b.
False
True
1
A constrained problem
5. Nonlinear optimization problems can have only one local optimal solution.
a.
True
b.
False
False
1
Capital budgeting
6. A feasible solution is a global optimum if there are no other feasible solutions with a better objective function value in
the immediate neighborhood.
a.
True
b.
False
False
1
Local and global optima
Chapter 8 – Nonlinear Optimization Models
7. A feasible solution is a global optimum if there are no other feasible points with a better objective function value in the
feasible region.
a.
True
b.
False
True
1
8. For a typical nonlinear problem, duals price are relatively insensitive to small changes in right-hand side values.
a.
True
b.
False
False
1
9. The interpretation of the dual price for nonlinear models is different than the interpretation of the dual price for linear
models.
a.
True
b.
False
False
1
10. In the case of functions with multiple local optima, most nonlinear optimization software methods can get stuck and
terminate at a local optimum.
a.
True
b.
False
True
1
11. For a minimization problem, a point is a global minimum if there are no other feasible points with a smaller objective
function value.
a.
True
b.
False
True
1
12. There are nonlinear applications in which there is a single local optimal solution that is also the global optimal
solution.
a.
True
b.
False
True
1
Chapter 8 – Nonlinear Optimization Models
13. Functions that are convex have a single local maximum that is also the global maximum.
a.
True
b.
False
False
1
14. The function f (X, Y) = X 2 + Y 2 has a single global minimum and is relatively easy to minimize.
a.
True
b.
False
True
1
15. The problem of maximizing a concave quadratic function over a linear constraint set is relatively difficult to solve.
a.
True
b.
False
False
1
16. Each point on the efficient frontier is the maximum possible risk, measured by portfolio variance, for the given return.
a.
True
b.
False
False
1
17. Any feasible solution to a blending problem with pooled components is feasible to the problem with no pooling.
a.
True
b.
False
True
1
18. Any feasible solution to a blending problem without pooled components is feasible to the problem with pooled
components.
a.
True
b.
False
False
Chapter 8 – Nonlinear Optimization Models
19. When components (or ingredients) in a blending problem must be pooled, the number of feasible solutions is reduced.
a.
True
b.
False
True
1
Blending – the pooling problem
20. The value of the coefficient of imitation, q, in the Bass model for forecasting adoption of a new product cannot be
negative.
a.
True
b.
False
False
1
Forecasting adoption of a new product
21. The Markowitz mean-variance portfolio model presented in the text is a convex optimization problem.
a.
True
b.
False
True
1
Markowitz portfolio model
22. Because most nonlinear optimization codes will terminate with a local optimum, the solution returned by the codes
will be the best solution.
a.
True
b.
False
False
1
Local and global optima
23. It is possible for the optimal solution to a nonlinear optimization problem to lie in the interior of the feasible region.
a.
True
b.
False
True
1
Nonlinear optimization models
Multiple Choice
24. Which of the following is incorrect?
a.
A global optimum is a local optimum in a nonlinear optimization problem.
b.
A local maximum is a global maximum in a concave nonlinear optimization problem.
c.
A global minimum is a local minimum in a convex nonlinear optimization problem.
d.
A local optimum is a global optimum in a nonlinear optimization problem.
d
1
Chapter 8 – Nonlinear Optimization Models
25. The measure of risk most often associated with the Markowitz portfolio model is the
a.
portfolio average return.
b.
portfolio minimum return.
c.
portfolio variance.
d.
portfolio standard deviation.
1
Markowitz portfolio model
26. An investor can pick the mean-variance tradeoff that he or she is most comfortable with by looking at a graph of the
a.
feasible region.
b.
pooled components.
c.
rolling horizon.
d.
efficient frontier.
d
1
Markowitz portfolio model
27. Which of the following is not a parameter of the Bass model for forecasting adoption of a new product?
a.
the coefficient of innovation
b.
the coefficient of interaction
c.
the coefficient of imitation
d.
the estimated number of people to eventually adopt the new product
b
1
Forecasting adoption of a new product
28. When the number of blending components exceeds the number of storage facilities, the number of feasible solutions to
the blending problem
a.
is reduced.
b.
is increased.
c.
is unchanged.
d.
is zero.
1
Blending – the pooling problem
29. In the Bass model for forecasting the adoption of a new product, the objective function
a.
minimizes the sum of forecast errors.
b.
minimizes the sum of squared forecast errors.
c.
maximizes the number of adoptions.
d.
maximizes the number of adoptions and imitations.
b
Local and global optima
Chapter 8 – Nonlinear Optimization Models
30. Which of the following is not true regarding a concave function?
a.
It is bowl-shaped down.
b.
It is relatively easy to maximize.
c.
It has multiple local maxima.
d.
It has a single global maximum.
c
1
Local and global optima
31. A convex function is
a.
bowl-shaped up.
b.
bowl-shaped down.
c.
elliptical in shape.
d.
sinusoidal in shape.
a
1
Local and global optima
32. If the coefficient of each squared term in a quadratic function is positive, the function is
a.
concave.
b.
convex.
c.
elliptical.
d.
sinusoidal.
b
1
Local and global optima
33. Components that share a storage facility are called
a.
constrained components.
b.
indexed components.
c.
blended components.
d.
pooled components.
d
1
Blending – the pooling problem
34. The key idea behind constructing an index fund is to choose a portfolio of securities that
a.
is a mix of growth-oriented and income-oriented stocks.
b.
minimizes risk without sacrificing liquidity.
c.
mimics the performance of a broad market index.
d.
balances short-term and long-term investments.
c
1
Forecasting adoption of a new product
Chapter 8 – Nonlinear Optimization Models
35. Components are referred to as pooled if they
a.
are shared by two or more customers
b.
have common ingredients
c.
share a storage facility
d.
are interchangeable
1
Blending: the pooling problem
Subjective Short Answer
36. Investment manager Max Gaines has several clients who wish to own a mutual fund portfolio that matches, as a
whole, the performance of the S&P 500 stock index. His task is to determine what proportion of the portfolio should be
invested in each of the five mutual funds listed below so that the portfolio most closely mimics the performance of the
S&P 500 index. Formulate the appropriate nonlinear program.
Annual Returns (Planning Scenarios)
Mutual Fund
Year 1
Year 2
Year 3
Year 4
International Stock
26.73
22.37
6.46
−3.19
Large-Cap Blend
18.61
14.88
10.52
5.25
Mid-Cap Blend
18.04
19.45
15.91
−1.94
Small-Cap Blend
11.33
13.79
−2.07
6.85
Intermediate Bond
8.05
7.29
9.18
3.92
S&P 500 Index
21.00
19.00
12.00
4.00
1
Constructing an index fund
37. Financial planner Minnie Margin has a substantial number of clients who wish to own a mutual fund portfolio that
matches, as a whole, the performance of the Russell 2000 index. Her task is to determine what proportion of the portfolio
should be invested in each of the five mutual funds listed below so that the portfolio most closely mimics the performance
of the Russell 2000 index. Formulate the appropriate nonlinear program.
1
Constructing an index fund
Chapter 8 – Nonlinear Optimization Models
Annual Returns (Planning Scenarios)
Mutual Fund
Year 1
Year 2
Year 3
Year 4
International Stock
22.37
26.73
4.86
2.17
Large-Cap Value
15.48
19.64
11.50
−5.25
Mid-Cap Value
17.42
20.07
−4.97
−1.69
Small-Cap Growth
23.18
12.36
3.25
3.81
Short-Term Bond
9.26
8.81
6.15
4.04
Russell 2000 Index
20.00
22.00
8.00
−2.00
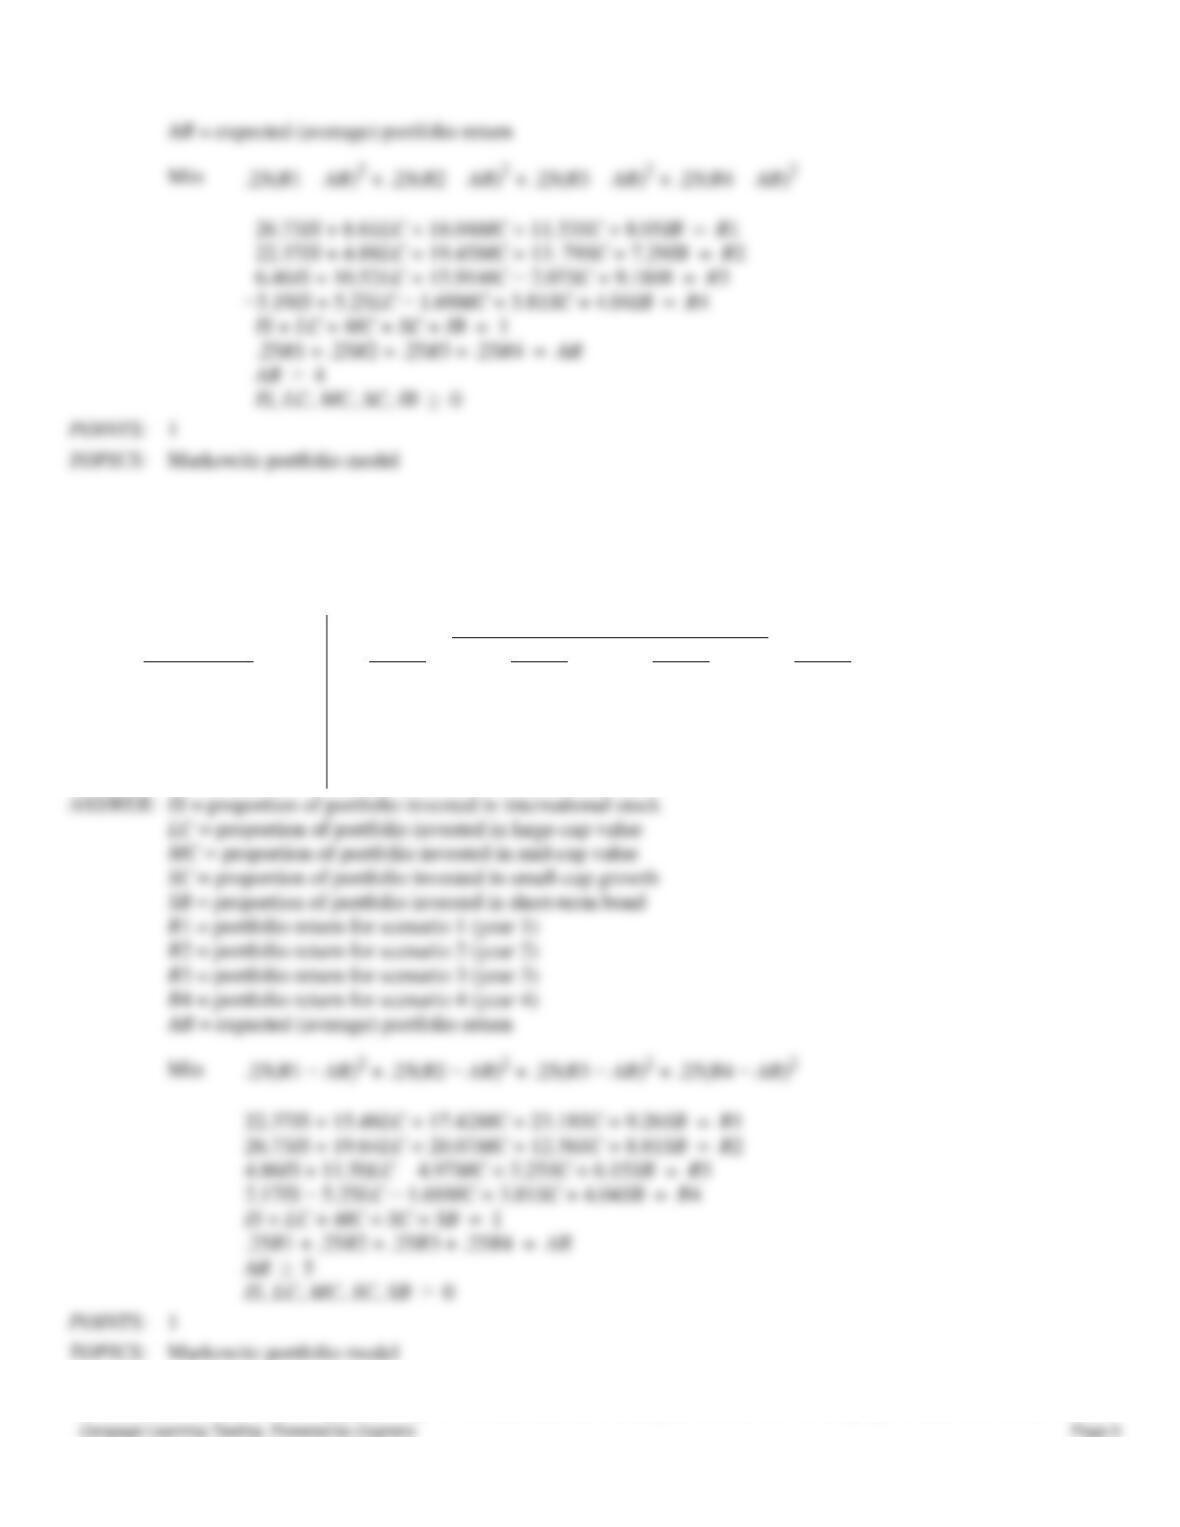
38. Investment manager Max Gaines wishes to develop a mutual fund portfolio based on the Markowitz portfolio model.
He needs to determine the proportion of the portfolio to invest in each of the five mutual funds listed below so that the
variance of the portfolio is minimized subject to the constraint that the expected return of the portfolio be at least 4%.
Formulate the appropriate nonlinear program.
Annual Returns (Planning Scenarios)
Mutual Fund
Year 1
Year 2
Year 3
Year 4
International Stock
26.73
22.37
6.46
−3.19
Large-Cap Blend
18.61
14.88
10.52
5.25
Mid-Cap Blend
18.04
19.45
15.91
−1.94
Small-Cap Blend
11.33
13.79
−2.07
6.85
Intermediate Bond
8.05
7.29
9.18
3.92
Chapter 8 – Nonlinear Optimization Models
39. Financial planner Minnie Margin wishes to develop a mutual fund portfolio based on the Markowitz portfolio model.
She needs to determine the proportion of the portfolio to invest in each of the five mutual funds listed below so that the
variance of the portfolio is minimized subject to the constraint that the expected return of the portfolio be at least 5%.
Formulate the appropriate nonlinear program.
Annual Returns (Planning Scenarios)
Mutual Fund
Year 1
Year 2
Year 3
Year 4
International Stock
22.37
26.73
4.86
2.17
Large-Cap Value
15.48
19.64
11.50
−5.25
Mid-Cap Value
17.42
20.07
−4.97
−1.69
Small-Cap Growth
23.18
12.36
3.25
3.81
Short-Term Bond
9.26
8.81
6.15
4.04
1
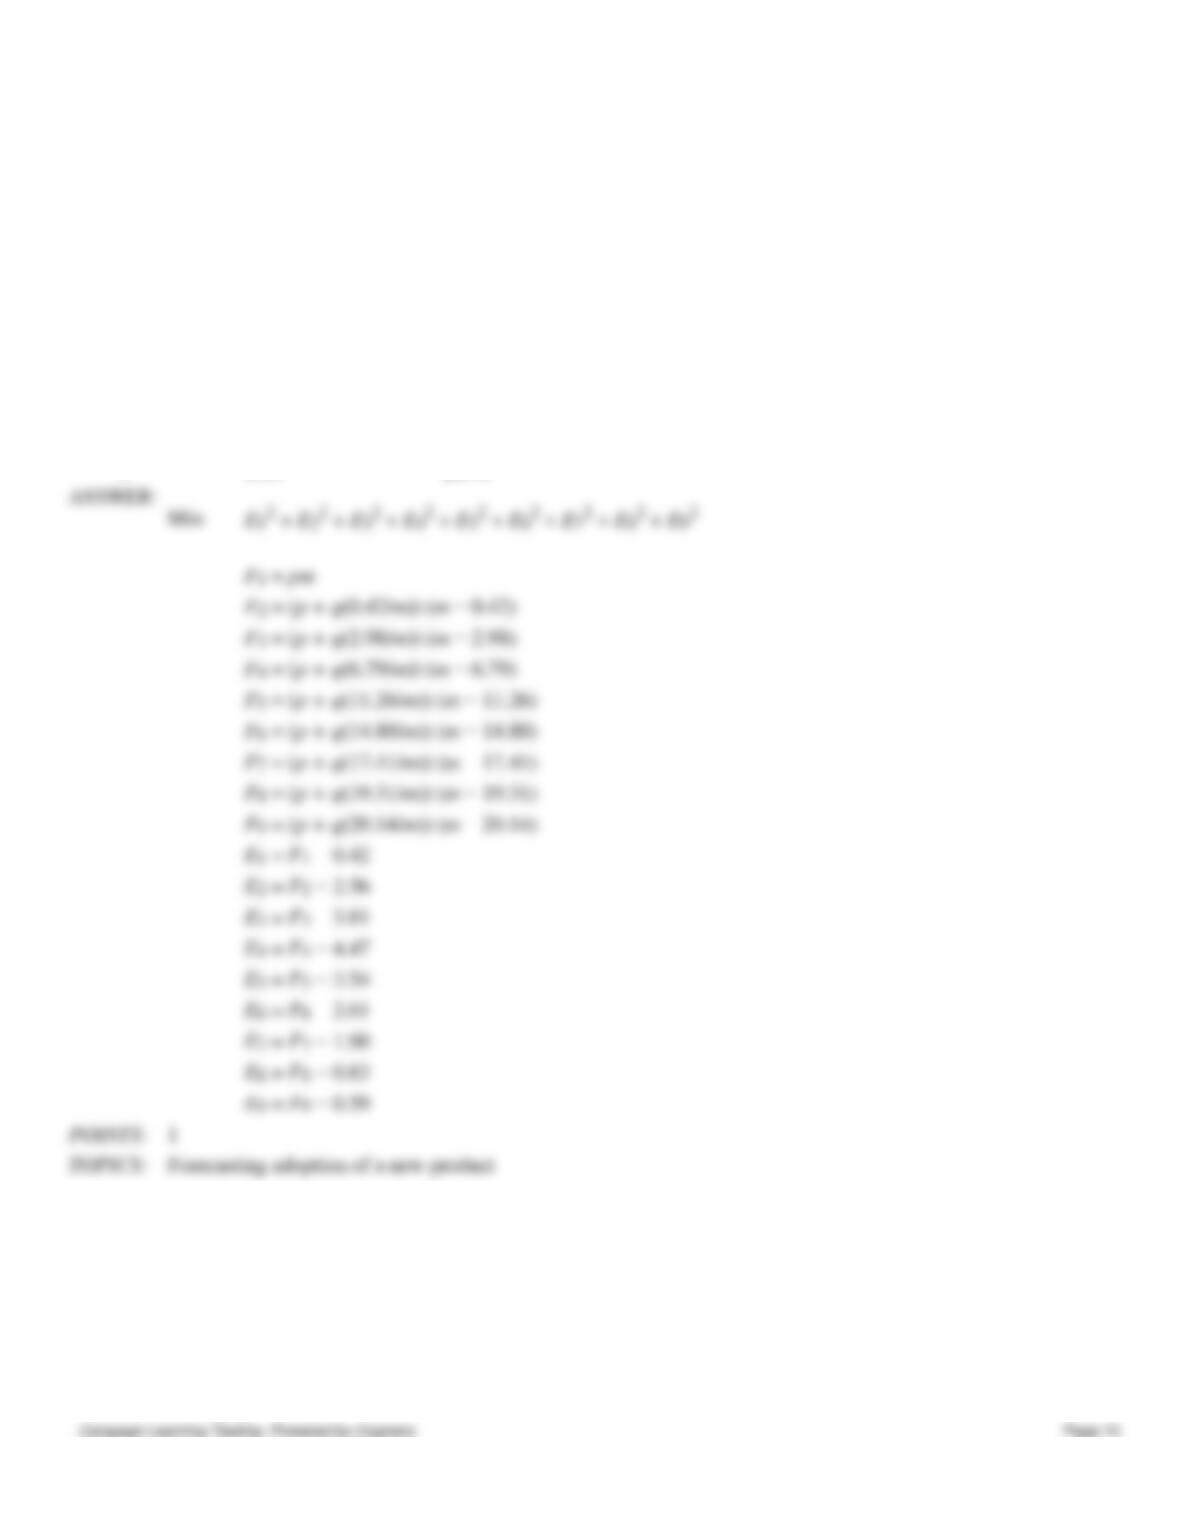
40. Shampooch is a mobile dog grooming service firm that has been quite successful developing a client base in the Dallas
1
Chapter 8 – Nonlinear Optimization Models
area. The firm plans to expand to other cities in Texas during the next few years. Shampooch would like to use its Dallas
subscription data shown below to develop a model for forecasting service subscriptions in cities where it might expand.
The first step is to estimate values for p (coefficient of innovation) and q (coefficient of imitation). Formulate the
appropriate nonlinear program.
Month
Subscribers St
Cum. Subscribers Ct
1
0.42
0.42
2
2.56
2.98
3
3.81
6.79
4
4.47
11.26
5
3.54
14.80
6
2.61
17.41
7
1.90
19.31
8
0.83
20.14
9
0.59
20.73
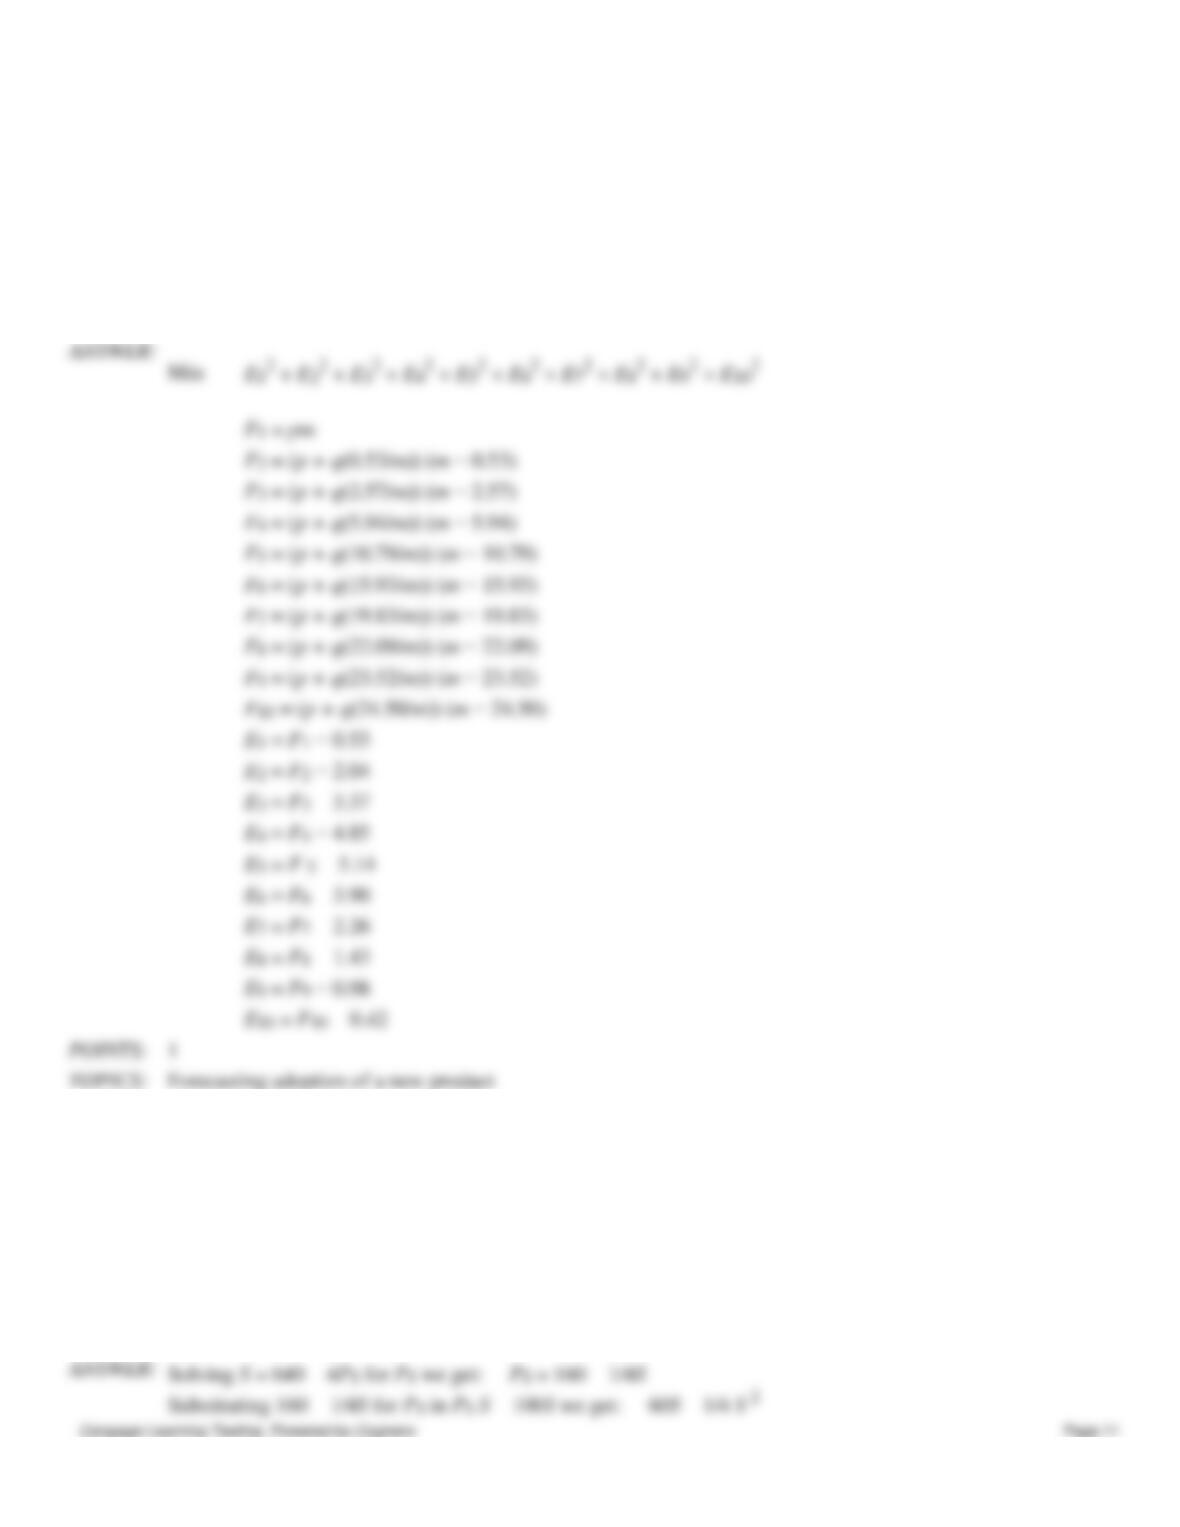
41. Cutting Edge Yard Care is a residential and commercial lawn service company that has been in business in the Atlanta
metropolitan area for almost one year. Cutting Edge would like to use its Atlanta service subscription data below to
develop a model for forecasting service subscriptions in other metropolitan areas where it might expand. The first step is
to estimate values for p (coefficient of innovation) and q (coefficient of imitation). Formulate the appropriate nonlinear
program.
Month
Subscribers St
Cum. Subscribers Ct
1
0.53
0.53
Chapter 8 – Nonlinear Optimization Models
2
2.04
2.57
3
3.37
5.94
4
4.85
10.79
5
5.14
15.93
6
3.90
19.83
7
2.26
22.09
8
1.43
23.52
9
0.98
24.50
10
0.42
24.92
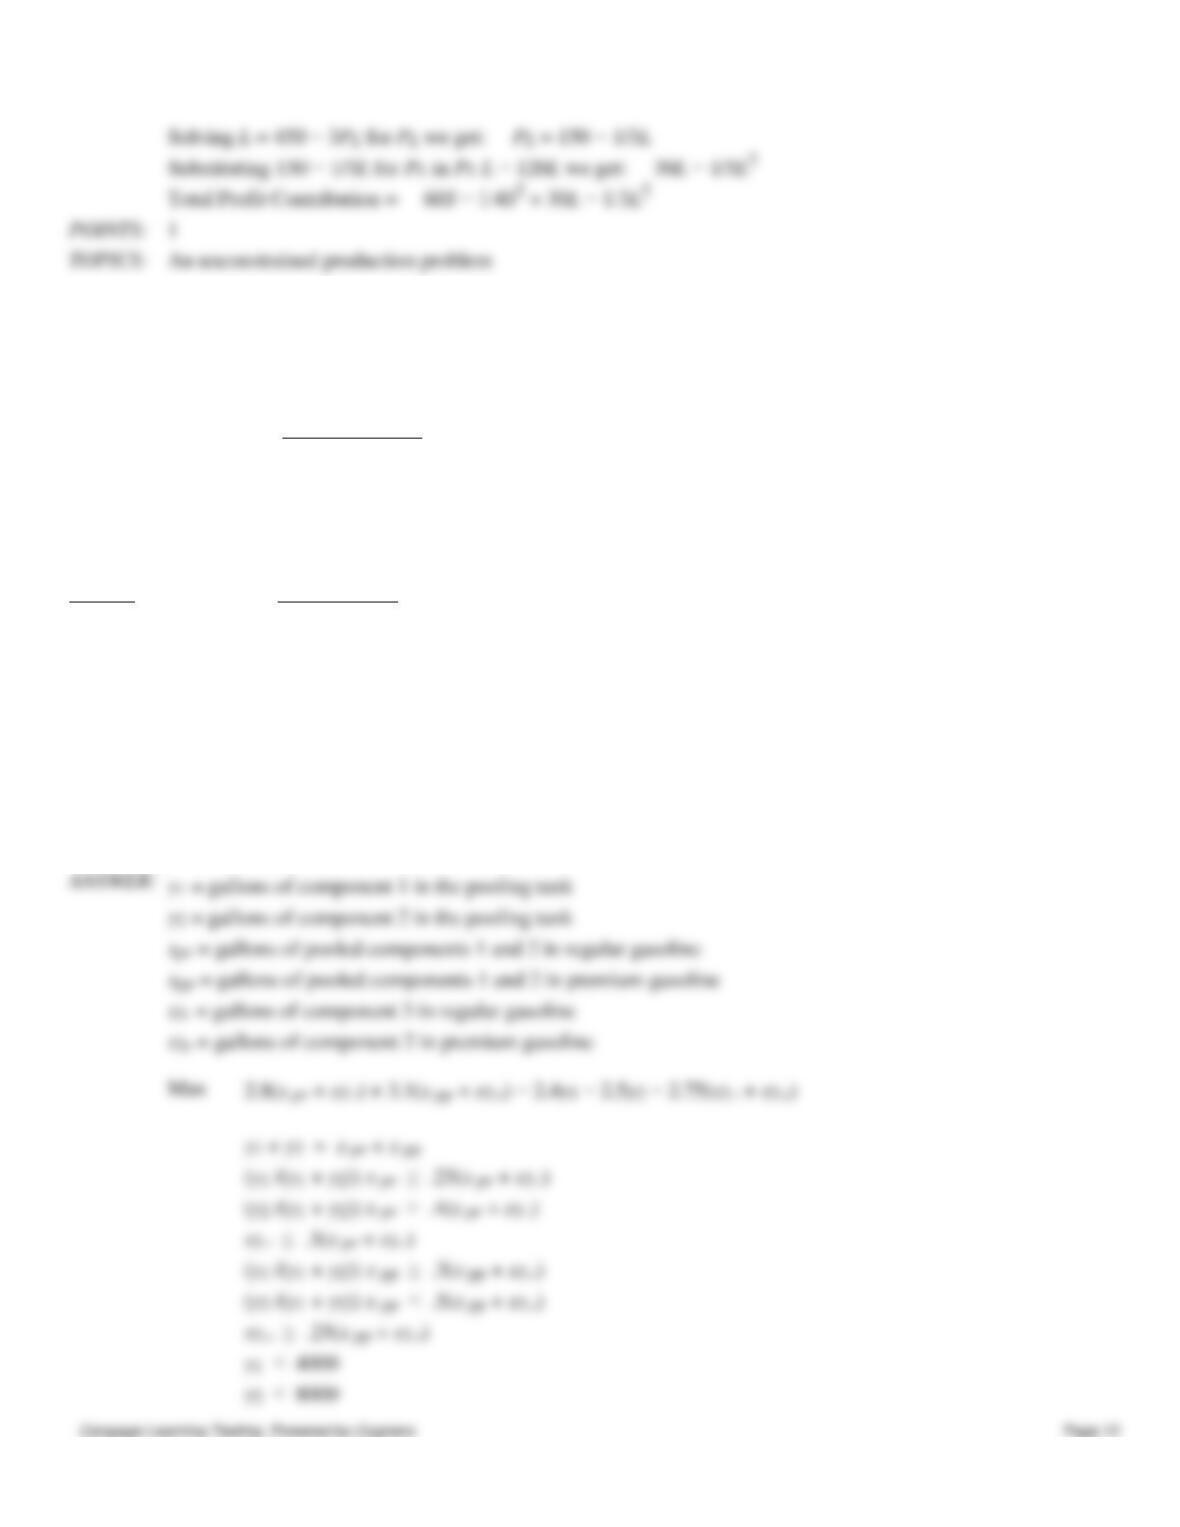
42. MegaSports, Inc. produces two high-priced metal baseball bats, the Slugger and the Launcher, that are made from
special aluminum and steel alloys. The cost to produce a Slugger bat is $100, and the cost to produce a Launcher bat is
$120. We can not assume that MegaSports will sell all the bats it can produce. As the selling price of each bat model —
Slugger and Launcher — increases, the quantity demanded for each model goes down.
Assume that the demand, S, for Slugger bats is given by S = 640 − 4PS and the demand, L, for Launcher bats is given by L
= 450 − 3PL where PS is the price of a Slugger bat and PL is the price of a Launcher bat. The profit contributions are PS S
− 100S for Slugger bats and PL L − 120L for Launcher bats. Develop the total profit contribution function for this
problem.
Chapter 8 – Nonlinear Optimization Models
43. Pacific-Gulf Oil Company is faced with the problem of refining three petroleum components into regular and
premium gasoline in order to maximize profit. Components 1 and 2 are pooled in a single storage tank and component 3
has its own storage tank. Regular and premium gasolines are made from blending the pooled components and component
3. Prices per gallon for the two products and three components, as well as product specifications, are listed below.
Price Per Gallon
Regular gasoline
$2.80
Premium gasoline
3.10
Component 1
2.40
Component 2
2.50
Component 3
2.75
Product
Specifications
Regular gasoline
At most 25% component 1
At least 40% component 2
At most 30% component 3
Premium gasoline
At least 30% component 1
At most 50% component 2
At least 25% component 3
The maximum number of gallons available for each of the three components is 4000, 8000, and 8000, respectively.
Formulate a nonlinear program to determine: 1) what percentages of component 1 and component 2 should be used in the
pooled mixture, and 2) how to make regular and premium gasoline by blending the mixture of components 1 and 2 from
the pooling tank with component 3.
Chapter 8 – Nonlinear Optimization Models
44. Skooter’s Skateboards produces two models of skateboards, the FX and the ZX. Skateboard revenue (in $l,000s) for
the firm is nonlinear and is stated as (number of FXs)(5 − 0.2 number of FXs) + (number of ZXs)(7 − 0.3 number of
ZXs). Skooter’s has 80 labor-hours available per week in its paint shop. Each FX requires 2 labor-hours to paint and each
ZX requires 3 labor-hours. Formulate this nonlinear production planning problem to determine how many FX and ZX
skateboards should be produced per week at Scooter’s.
45. Native Customs sells two popular styles of hand–sewn footwear: a sandal and a moccasin. The cost to make a pair of
sandals is $18, and the cost to make a pair of moccasins is $24. The demand for these two items is sensitive to the price,
and historical data indicate that the monthly demands are given by S = 400 − 10P1 and M = 450 − 15P2 , where S =
demand for sandals (in pairs), M = demand for moccasins (in pairs), P1 = price for a pair of sandals, and P2 = price for a
pair of moccasins. To remain competitive, Native Customs must limit the price (per pair) to no more than $60 and $75 for
its sandals and moccasins, respectively. Formulate this nonlinear programming problem to find the optimal production
quantities and prices for sandals and moccasins that maximize total monthly profit.
46. Explain how the local minimum, local maximum, local optimum, global minimum, global maximum, and global
optimum relate to one another in nonlinear optimization problems.
Chapter 8 – Nonlinear Optimization Models
47. Explain how the parameters required for the Bass new-product adoption model can be estimated when no historical
data are available for the new product.
48. Describe how the Markowitz portfolio model can be modified to account for upper and lower bounds being placed on
the amount of an asset type invested in the portfolio.
49. Provide several examples of both nonlinear objective functions and nonlinear constraints.
50. Discuss the essence of the pooling problem in terms of the circumstances, objective, and constraint
51. Describe the difference between a convex function and a concave function and give an example of each.